# Holybro Pix32 v5
:::warning
PX4 does not manufacture this (or any) autopilot.
Contact the [manufacturer](https://holybro.com/) for hardware support or compliance issues.
:::
[Pix32 v5](https://holybro.com/products/pix32-v5)® is an advanced autopilot flight controller designed and made by Holybro®.
It is optimized to run on PX4 firmware, which is intended for both academic and commercial developers.
It is based on the [Pixhawk-project](https://pixhawk.org/) **FMUv5** open hardware design and runs PX4 on the [NuttX](https://nuttx.apache.org/) OS.
It can be regarded as a variant version of Pixhawk4.
The Pix32 v5 is designed for pilots who need a high power, flexible and customisable flight control system.
It is comprised of a separate flight controller and carrier (base) board, which are connected by a 100pin connector.
This design allows users to either select a base board made by Holybro, or customize their own.

:::info
This flight controller is [manufacturer supported](../flight_controller/autopilot_manufacturer_supported.md).
:::
## 总览
- 主处理器:STM32F765
- 32 位 Arm® Cortex®-M7,216MHz,2MB 储存,512KB RAM
- IO 处理器:STM32F100
- 32 位 Arm® Cortex®-M3,24MHz,8KB SRAM
- 内置传感器:
- 加速度计 / 陀螺仪:ICM-20689
- Accel/Gyro: BMI055 or ICM20602
- 磁力计:IST8310
- 气压计:MS5611
- GPS:ublox Neo-M8N GPS/GLONASS 接收器;集成磁力计 IST8310
- 接口:
- 8-16 路PWM输出(8路来自 IO,8路来自 FMU)
- FMU上有3个专用PWM/Capture输入
- CPPM专用的RC输入
- 用于 Spektrum / DSM 与 有模拟 / PWM RSSI 的 S.Bus 的专用遥控输入
- Dedicated S.Bus servo output
- 5个通用串行口
- 2 with full flow control
- 1 with separate 1.5A current limit
- 3 个 I2C 接口
- 4路SPI总线
- 1 internal high speed SPI sensor bus with 4 chip selects and 6 DRDYs
- 1 internal low noise SPI bus dedicated for
- Barometer with 2 chip selects, no DRDYs
- 1 internal SPI bus dedicated for FRAM
- Supports dedicated SPI calibration EEPROM located on sensor module
- 1 external SPI buses
- 多达 2 路 CAN 总线用于带串口的电调
- Each CANBus has individual silent controls or ESC RX-MUX control
- 2个电池电流/电压模拟输入口
- 2 additional analog inputs
- Electrical System:
- 电源模块输出:4.9~5.5V
- Max input voltage: 6V
- 最大电流感应:120A
- USB 电源输入:4.75~5.25V
- 伺服导轨输入电压:0~36V
- 重量和尺寸:
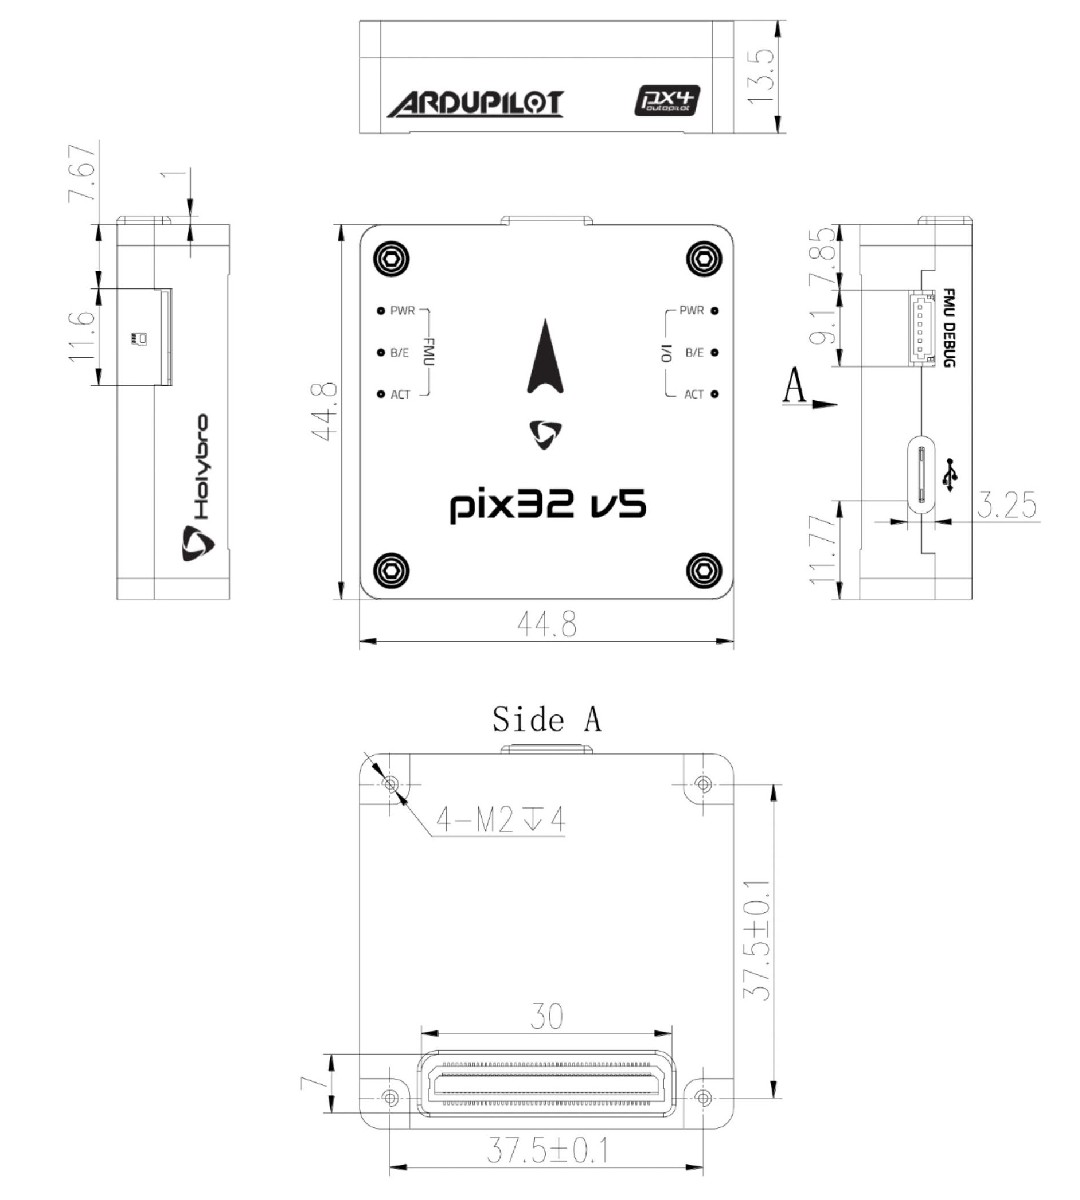
- Dimensions: 45x45x13.5mm
- Weight: 33.0g
- Environmental Data, Quality & Reliability:
- 工作温度:-40 ~ 85°C
- Storage temp. -40~85℃
- CE
- FCC
- RoHS compliant (lead-free)
Additional information can be found in the [Pix32 V5 Technical Data Sheet](https://cdn.shopify.com/s/files/1/0604/5905/7341/files/Holybro_PIX32-V5_technical_data_sheet_v1.1.pdf).
## 购买渠道
Order from [Holybro website](https://holybro.com/products/pix32-v5).
## 组装 / 设置
The [Pix32 v5 Wiring Quick Start](../assembly/quick_start_holybro_pix32_v5.md) provides instructions on how to assemble required/important peripherals including GPS, Power Management Board etc.
## Base Board Layouts

## 针脚定义
[_pix32 v5_ and mini baseboard](https://cdn.shopify.com/s/files/1/0604/5905/7341/files/Holybro_Pix32-V5-Base-Mini-Pinouts.pdf)
## 尺寸
## 额定电压
_Pix32 v5_ can be triple-redundant on the power supply if three power sources are supplied.
The three power rails are: **POWER1**, **POWER2** and **USB**.
:::info
The output power rails **FMU PWM OUT** and **I/O PWM OUT** (0V to 36V) do not power the flight controller board (and are not powered by it).
You must supply power to one of **POWER1**, **POWER2** or **USB** or the board will be unpowered.
:::
**Normal Operation Maximum Ratings**
Under these conditions all power sources will be used in this order to power the system:
1. **POWER1** and **POWER2** inputs (4.9V to 5.5V)
2. **USB** input (4.75V to 5.25V)
**Absolute Maximum Ratings**
Under these conditions the system will not draw any power (will not be operational), but will remain intact.
1. **POWER1** and **POWER2** inputs (operational range 4.1V to 5.7V, 0V to 10V undamaged)
2. **USB** input (operational range 4.1V to 5.7V, 0V to 6V undamaged)
3. Servo input: VDD_SERVO pin of **FMU PWM OUT** and **I/O PWM OUT** (0V to 42V undamaged)
## 编译固件
:::tip
Most users will not need to build this firmware!
It is pre-built and automatically installed by _QGroundControl_ when appropriate hardware is connected.
:::
To [build PX4](../dev_setup/building_px4.md) for this target:
```
make holybro_pix32v5_default
```
## 调试接口
The system's [serial console](../debug/system_console.md) and SWD interface runs on the **FMU Debug** port
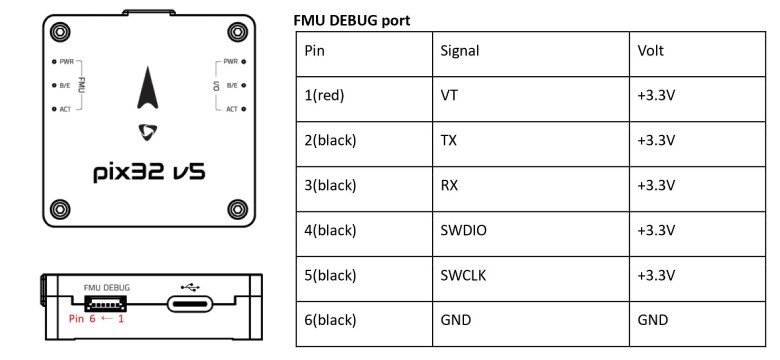
The pinout uses the standard [Pixhawk Debug Mini](../debug/swd_debug.md#pixhawk-debug-mini) interface defined in the [Pixhawk Connector Standard](https://github.com/pixhawk/Pixhawk-Standards/blob/master/DS-009%20Pixhawk%20Connector%20Standard.pdf).
## 外部设备
- [Digital Airspeed Sensor](../sensor/airspeed.md)
- [Telemetry Radio Modules](../telemetry/index.md)
- [Rangefinders/Distance sensors](../sensor/rangefinders.md)
## 支持的平台/机身
Any multicopter / airplane / rover or boat that can be controlled with normal RC servos or Futaba S-Bus servos.
The complete set of supported configurations can be seen in the [Airframes Reference](../airframes/airframe_reference.md).
## 附加信息
- [Pix32 v5 Technical Data Sheet](https://cdn.shopify.com/s/files/1/0604/5905/7341/files/Holybro_PIX32-V5_technical_data_sheet_v1.1.pdf)
- [Pix32 v5 Pinouts](https://cdn.shopify.com/s/files/1/0604/5905/7341/files/Holybro_Pix32-V5-Base-Mini-Pinouts.pdf)
- [Pix32 v5 Base Board Schematic Diagram](https://cdn.shopify.com/s/files/1/0604/5905/7341/files/Holybro_PIX32-V5-BASE-Schematic_diagram.pdf)
- [Pix32 v5 Mini Base Board Schematic Diagram](https://cdn.shopify.com/s/files/1/0604/5905/7341/files/Holybro_PIX32-V5-Base-Mini-Board_Schematic_diagram.pdf)
- [FMUv5 reference design pinout](https://docs.google.com/spreadsheets/d/1-n0__BYDedQrc_2NHqBenG1DNepAgnHpSGglke-QQwY/edit#gid=912976165).